The working environment
A rectangular keyed workpiece rests on tray T-04 in a supervised workcell. In the expected view, its raised locating boss is on the image right and its projecting tongue is on the left.
ROBOTICS & MACHINES
Identify a workpiece, check its orientation and flag obstructions before a supervised task begins.
VISION IN CONTEXT / 03
Follow a workpiece into a vision workcell, review its visible orientation, and separate information confirmation from a preset motion concept.
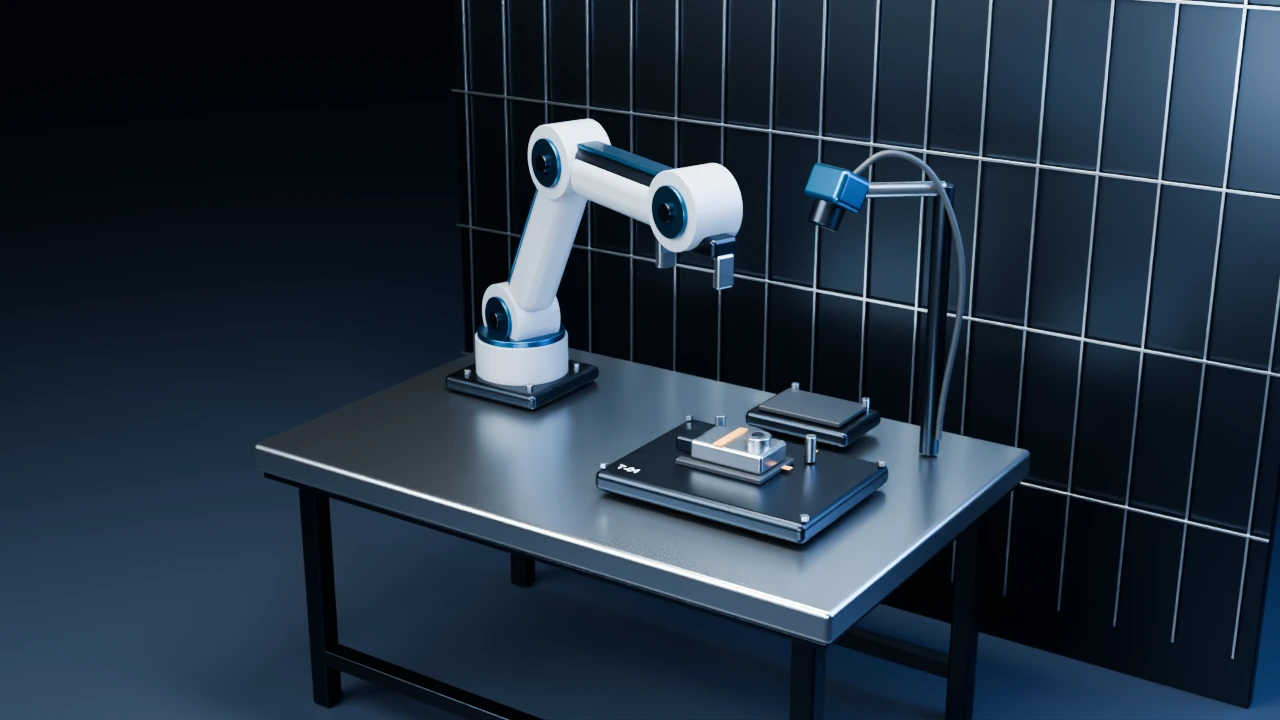
The camera observes a target within a fixture and working envelope. Visual information is one input to the existing control process.
The camera movement explains the scene. The fixed evidence view below is a separate synthetic capture, with no live inference.
FROM OBSERVATION TO A DECISION
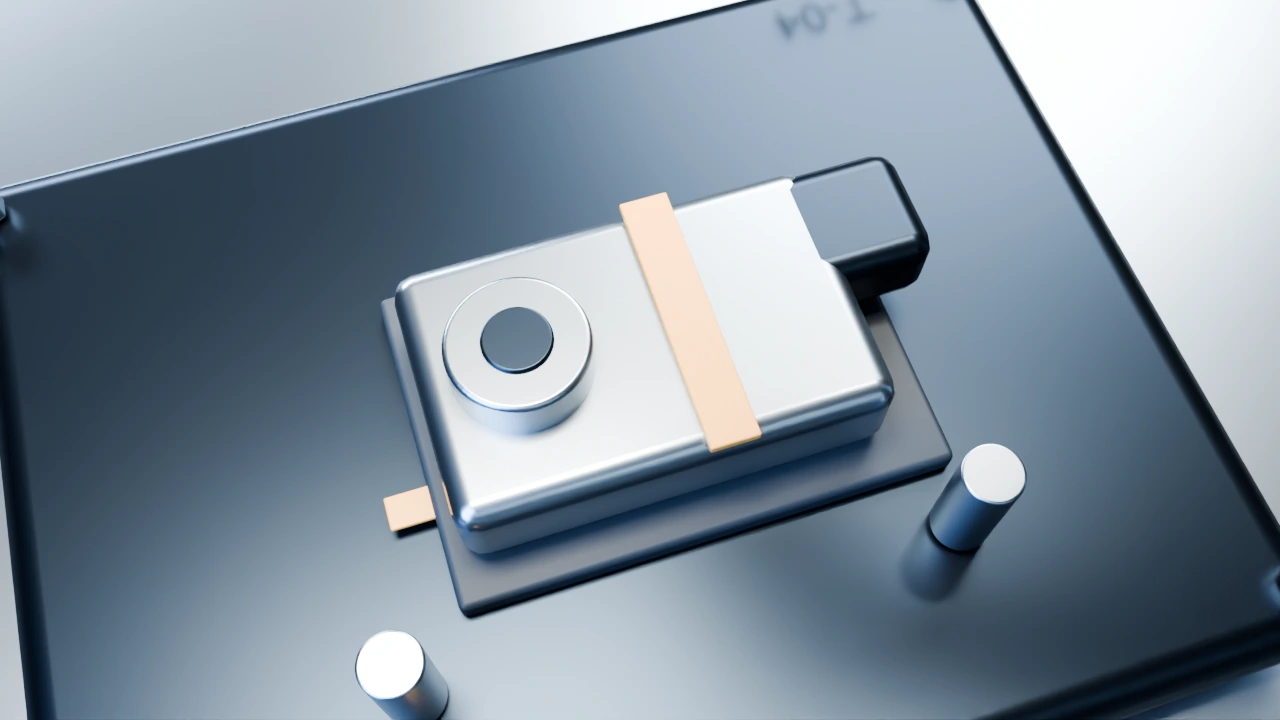 Workpiece locating feature
THE NEXT STEP NEEDS CONTEXT
Choose the expected orientation and confirm its visible information to unlock the prerecorded example.
PRESET VIDEO / NO EQUIPMENT CONNECTION
Our machine-vision direction covers workpiece orientation in an incoming tray, obscured locating features at an assembly station and visible seating after placement. The visual layer helps operators and integrators distinguish a usable observation from a view that needs attention.
A rectangular keyed workpiece rests on tray T-04 in a supervised workcell. In the expected view, its raised locating boss is on the image right and its projecting tongue is on the left.
The operator checks the selected workpiece and its orientation. The integrator defines how the visual result is passed to the existing workstation.
A workpiece can arrive rotated by 180 degrees or with its locating boss obscured. The offset boss and projecting tongue distinguish the two visible orientations.
The concept associates the workpiece with tray T-04 and compares the boss and tongue positions with the task reference. If the boss is hidden, it flags the observation gap and requests another view.
Show the operator the fixture position, orientation finding and any obscured feature. The approved workstation process determines the next equipment action.
Help the operator correct the particular workpiece presentation or view that prevents a clear decision. A later image can check the same workpiece after it has been placed.
ILLUSTRATIVE WORKFLOWS — the following records are fictional examples, not customer cases or live analysis.
The same rectangular workpiece fits within the tray outline in either orientation. Check both the offset boss and projecting tongue before confirming its presentation for the next task.
Capture the workpiece and T-04 tray from a repeatable camera view. Retain the tray identifier and references showing the boss on the right with the tongue on the left, and the opposite orientation.
The proposed task locates the workpiece and compares the boss and tongue positions with the reference. Highlight the locating feature so the operator can see why the orientation needs review.
Prepare the compartment ID, selected-object crop and orientation finding for the workstation display. Any pick or reorientation action stays with the approved operator and control workflow.
Show which workpiece needs reorientation and which feature determines that result, rather than asking the operator to inspect every tray item again.
A temporary cover, label or fixture component may obscure the locating boss. A hidden feature does not establish the workpiece orientation or mean that the feature is missing.
Capture the workpiece and tray together from the station camera. Use the same part variant with its locating boss visible, partly covered and fully hidden.
The concept marks the expected locating-feature region and records the coverage gap. It leaves orientation unresolved until a clear view or operator check is available.
Show the blocked region to the operator and request a permitted clearer view. The station’s existing procedure determines any fixture or part adjustment.
Tell the operator that the view needs attention, not that the workpiece is necessarily wrong, and show exactly which region must become visible.
A completed placement cycle does not show whether a workpiece sits against the intended locating faces. A visible raised edge or offset may need an operator check.
Capture the placed workpiece and fixture datums from an agreed oblique view. Keep the cycle identifier and a reference image of the expected visible seating.
The proposed task aligns the fixture features and compares the workpiece edges with the reference. It highlights a visible gap or offset for the operator to examine.
Attach the marked edge and result image to the cycle entry. After an authorised adjustment, a new image can check whether the same visible mismatch remains.
Direct the operator to the raised corner or offset edge before the next assembly step, with a clear visual point to recheck.
The scope is agreed for the specific task. These are deliverables to define together, not a claim that a configured system is already available.
Workpiece variants, offset locating bosses, projecting tongues and tray identifiers, with reference views for each permitted presentation.
Overhead and oblique views that reveal orientation, fixture overlap and visible seating after placement.
Selected object, tray or fixture ID, marked feature, orientation or visibility result, and the next review step.
Test reversed workpieces, obscured locating bosses and raised edges; define the operator review and next capture for each condition.
An editable planning template, created on this device. Nothing is submitted.
No equipment is connected. The rendered scene illustrates orientation review. Confirming the expected-orientation example only unlocks a separate prerecorded motion clip; playback requires another click. Actual equipment remains within its approved control process.
Keep the image and mark the observation gap. The operator follows the station procedure to obtain a clearer view; the system should not infer an orientation from the hidden boss. Any new view needs a fresh review.
Yes. Use permitted images of the same workpiece in the required and opposite orientations, with obstruction and seating variations. These examples help define the camera view and result fields before a live station evaluation.
It can support the defined exterior check, such as whether an edge visibly meets a datum. Hidden engagement, holding force and safety functions require their own checks; the display should state which visible feature it assessed.
START WITH A SPECIFIC TASK
Discuss the environment, equipment and evidence your project needs.